Jaw End Position
Reliable detection of the open/closed jaw position on parallel grippers
Task
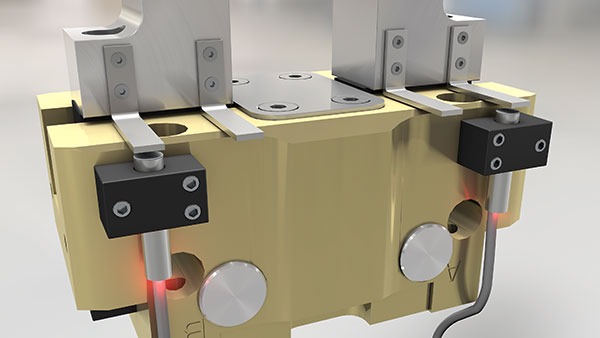
The open and closed state of the jaws needs to be detected.
Reliably detecting the end position (fully open or fully closed) of the jaws on parallel grippers is critical for verifying the gripping process and optimizing cycle times. Baumer's cylindrical and rectangular miniature inductive proximity switches solve this task reliably, providing high-precision position feedback in the smallest housing sizes.
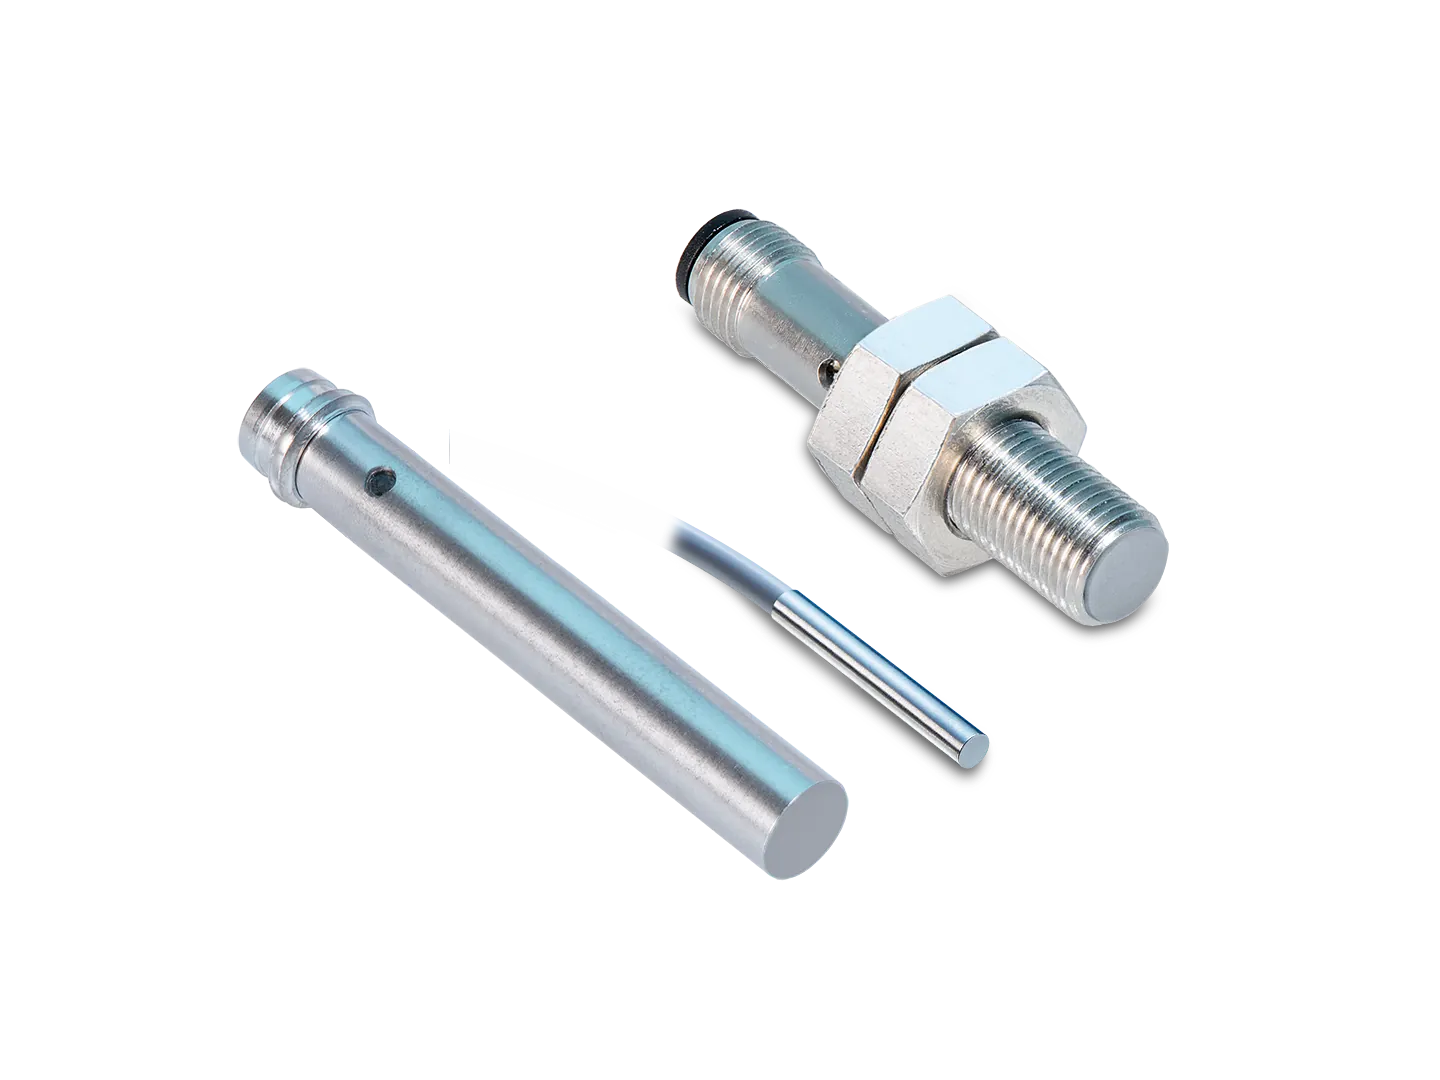
Cylindrical miniature sensors
Inductive proximity switches
- Diameters from 3 mm to 6 mm
- Short variants only 12 mm in length
- Switching distance of up to 6 mm
- Cable, pigtail cable, or connector variants
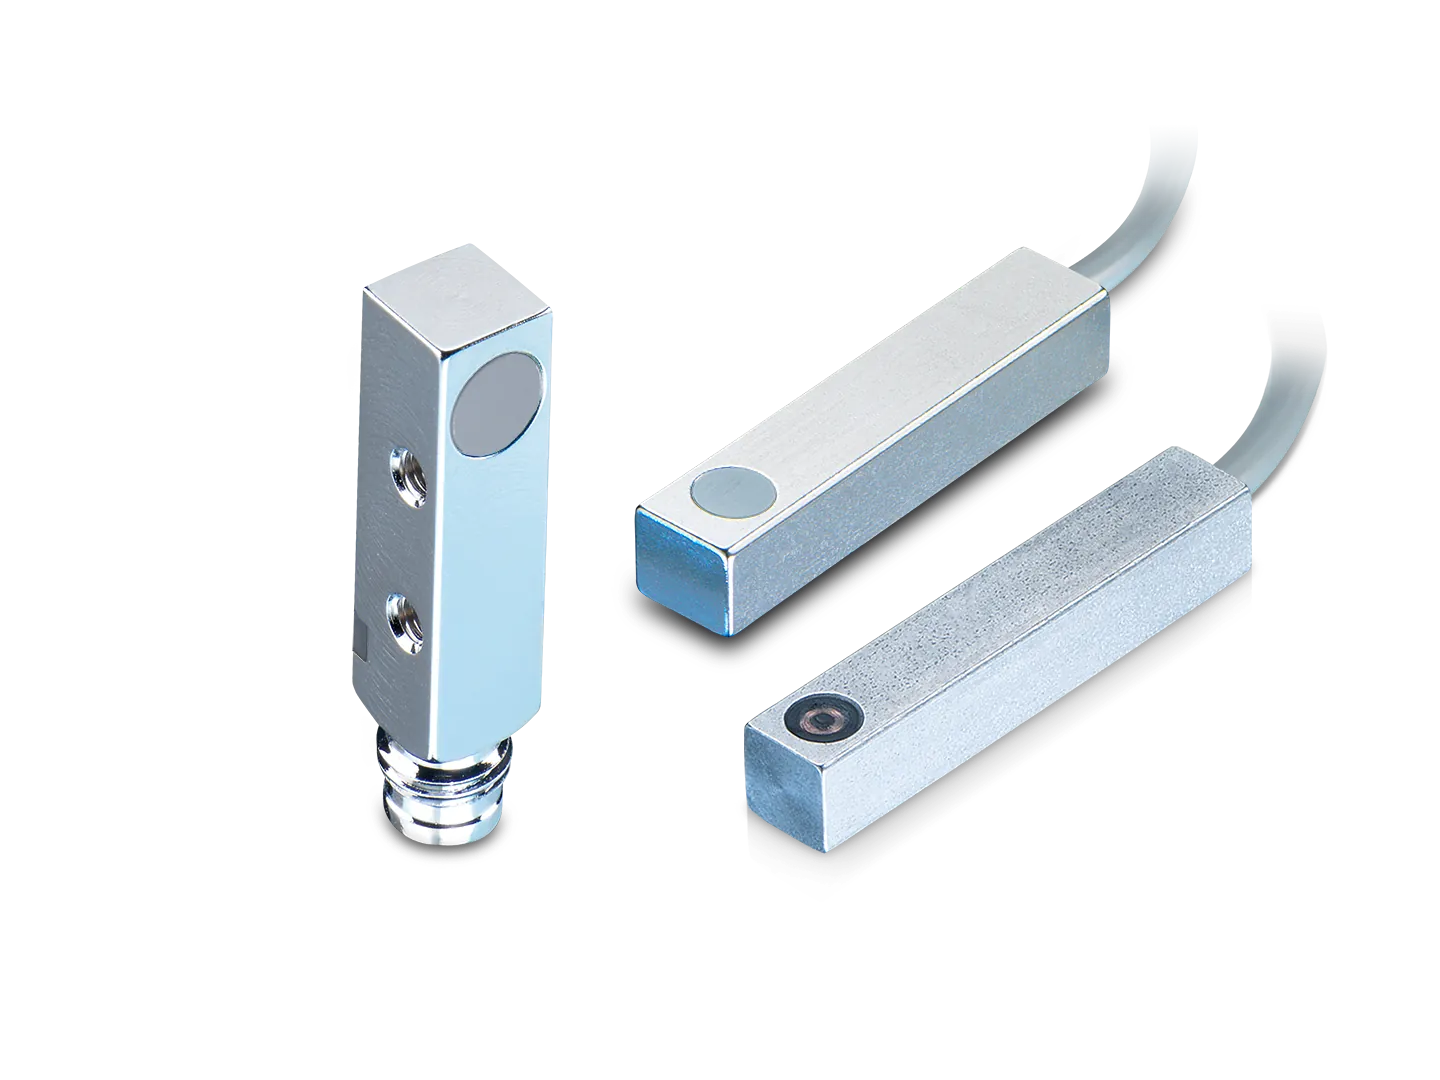
Rectangular miniature sensors
Inductive proximity switches
- 4x4, 6x6, and 8x8 mm designs
- Short variants only 20 mm in length
- Switching distance of up to 2 mm
- Cable and connector output variants
Learn more about robotic end-effector solutions
Explore our other sensor solutions for parallel grippers and automatic tool changers.
Back to Robotics SolutionsLooking for the right sensor solution for your robotics application?
Our expert team can help you identify the most suitable sensor technology for your end-effector and tool-changer applications.