Gripping Force
Indirect and reliable measurement of gripping force in parallel grippers.
Task
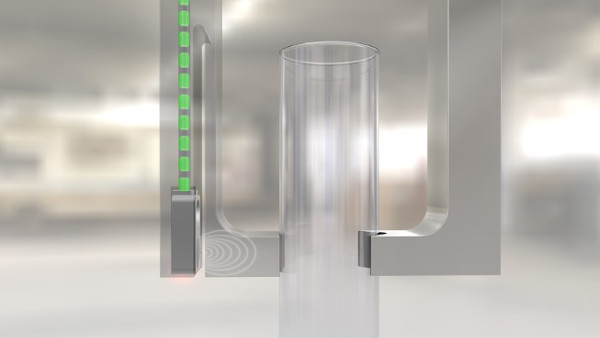
Indirect measurement of gripping force by measuring the displacement/deflection of a suitably designed finger during gripping.
A miniature inductive distance sensor integrated into the gripper finger measures the finger deflection with high precision, providing indirect and reliable feedback on gripping force.
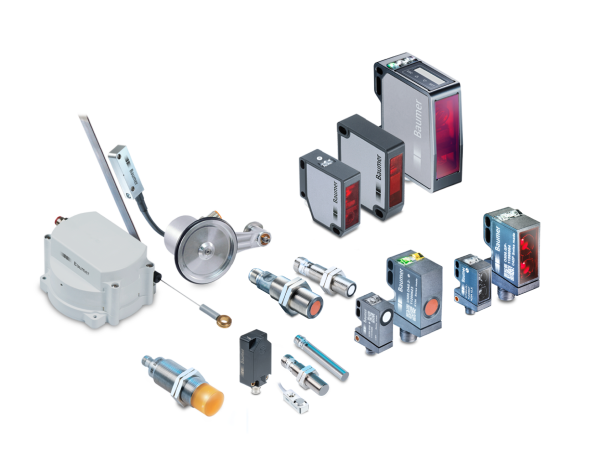
Recommended Products
Learn more about robotic end-of-arm tooling solutions
Explore our other sensor solutions for parallel grippers and automatic tool changers.
Back to Robotics SolutionsLooking for the right sensor solution for your robotics application?
Our expert team can help you determine the most suitable sensor technology for your end-of-arm tooling and tool changer applications.